Yukun Wang / 王宇堃

Yukun Wang — UCL MEng Robotics & AI, robot learning / embodied AI 王宇堃 — UCL MEng Robotics & AI,机器人学习 / 具身智能

I am a fourth-year MEng Robotics & AI student at University College London (UCL) and a Researcher in the UCL Humanoid Robotics Lab with Assoc. Prof. Chengxu Zhou, previously at Tsinghua IIIS × Zhongguancun Academy and UBTECH. I work on real-time humanoid motion generation and whole-body control (Unitree G1, NVIDIA SONIC), and on VLA policies trained with sim–real co-training and reinforcement learning (OpenVLA, NVIDIA GR00T N1.7).

我是伦敦大学学院(UCL)Robotics & AI 本硕连读(MEng)四年级学生,在 Chengxu Zhou 副教授的 UCL Humanoid Robotics Lab 担任 Researcher,曾在清华交叉信息研究院(IIIS)× 中关村学院、优必选(UBTECH)从事具身智能研究。研究方向:人形机器人实时动作生成与全身控制(Unitree G1、NVIDIA SONIC),以及 VLA 策略的虚实联合训练与强化学习(OpenVLA、NVIDIA GR00T N1.7)。

Humanoid Motion Generation · Whole-Body Control · VLA · Diffusion Policy · Reinforcement Learning · Sim2Real · Unitree G1 · GR00T · Isaac Sim人形动作生成 · 全身控制 · VLA · Diffusion Policy · 强化学习 · Sim2Real · Unitree G1 · GR00T · Isaac Sim

Portrait of Yukun Wang / 王宇堃

News动态

  • 2026.11

    AHEADance (co-first author), real-time streaming humanoid dance, is under review at IEEE T-RL. Project page

    AHEADance(共同一作)· 人形机器人实时流式舞蹈生成,IEEE T-RL 审稿中。项目主页

  • 2026.10

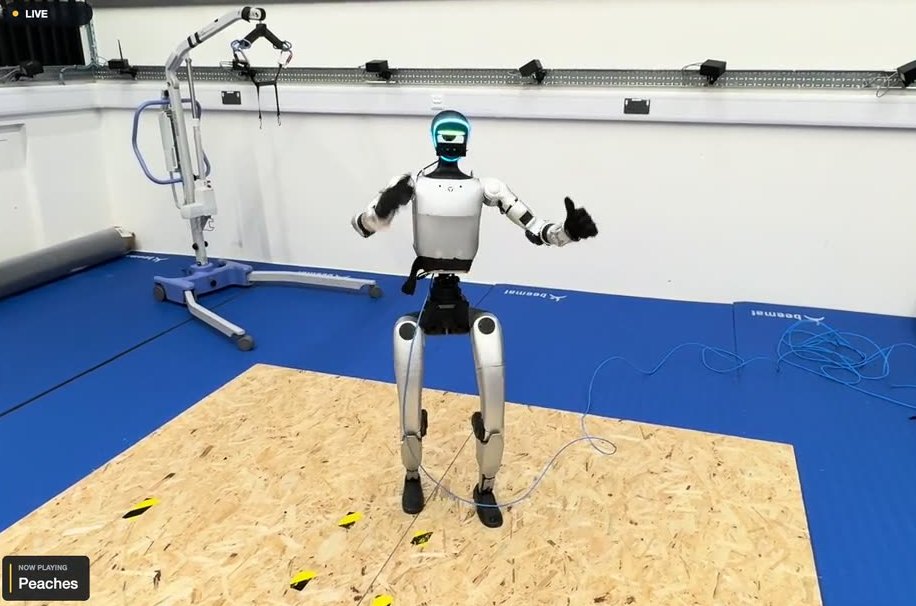
    AHEADance dances on a physical Unitree G1 to live music heard through a microphone.

    AHEADance 在 Unitree G1 真机上运行,通过麦克风听现场音乐起舞。

  • 2026.06 — 2026.10

    VLA / embodied AI intern at UBTECH: NVIDIA GR00T N1.7 post-training, a RECAP policy flywheel and training-time RTC on the UTars robot.

    在优必选任 VLA 具身智能算法实习生:NVIDIA GR00T N1.7 后训练、RECAP 策略飞轮与 Training-time RTC(UTars 双臂移动机器人)。

  • 2025.06 — 2025.10

    Research assistant at Tsinghua IIIS × Zhongguancun Academy: OpenVLA sim–real co-training with PPO, and Diffusion Policy on a real Franka arm.

    在清华交叉信息研究院 × 中关村学院任研究助理:OpenVLA 虚实联合训练(PPO)与 Franka 真机 Diffusion Policy。

Education教育

UCL

2023 — 2027 University College London · MEng (integrated master's) Robotics & AI伦敦大学学院(UCL)· Robotics & AI 本硕连读(MEng 硕士学位)

Paper论文

IEEE Transactions on Robot Learning · Under reviewIEEE T-RL(机器人学习最新顶刊)· 审稿中

AHEADance: Anticipatory Humanoid Dance from Streaming Audio

Real-time streaming humanoid dance: a robot that dances as it listens.边听边跳的人形机器人实时流式舞蹈生成

Tianhu Peng*, Yukun Wang*, Lingfan Bao, Yiyang Jia, Chengxu Zhou · UCL Humanoid Robotics Lab · *co-first authors*共同一作

Project page项目主页Video视频 ›arXiv soonarXiv 即将发布

HIGHLIGHTS项目亮点

A Unitree G1 that dances as it listens to streaming audio. Switch songs at any time, stop and restart the music, and it follows. One model dances many styles without being told the style, about 0.8 s behind the music, with no falls.

由流式音频驱动 Unitree G1 真机边听边跳:随时切歌、音乐随停随起,机器人都能跟上;同一模型无需告知曲风即可跳出多种舞蹈风格,端到端延迟约 0.8 秒,全程无摔倒。

RESULTS效果领先

On songs it never trained on, its dance quality is the best of all compared generators. Measured with our own music-sync detector, its timing and music matching beat offline methods that hear the whole song in advance, with music matching over 4× theirs. Its style and real-time switching beat online methods.

在训练未见歌曲上,舞蹈质量在所有对比方法中最优;经自研的音乐同步检测器评估,节奏同步与音乐匹配均超过需提前听完整首歌的 offline 方法,音乐匹配度达其他方法 4 倍以上;风格表现与实时切换均优于 online 方法。

HOW IT WORKS技术路线

ListenAhead uses a frozen music model (MRT-2) to forecast the coming beats. Commit Forcing trains the chunk-wise autoregressive diffusion model to continue from its own output, cutting stalled motion from 83.5% to 10.3%. NVIDIA SONIC whole-body control runs it on the robot.

ListenAhead 用冻结的音乐大模型 MRT-2 预测即将到来的节拍;Commit Forcing 让块间自回归、块内扩散的生成模型从自己生成的动作继续往下跳,停滞片段从 83.5% 降至 10.3%;最终由 NVIDIA SONIC 全身控制在真机上执行。

REAL ROBOT · FULL VIDEO真机 · 完整视频YouTube

Many styles, one model一个模型,多种风格

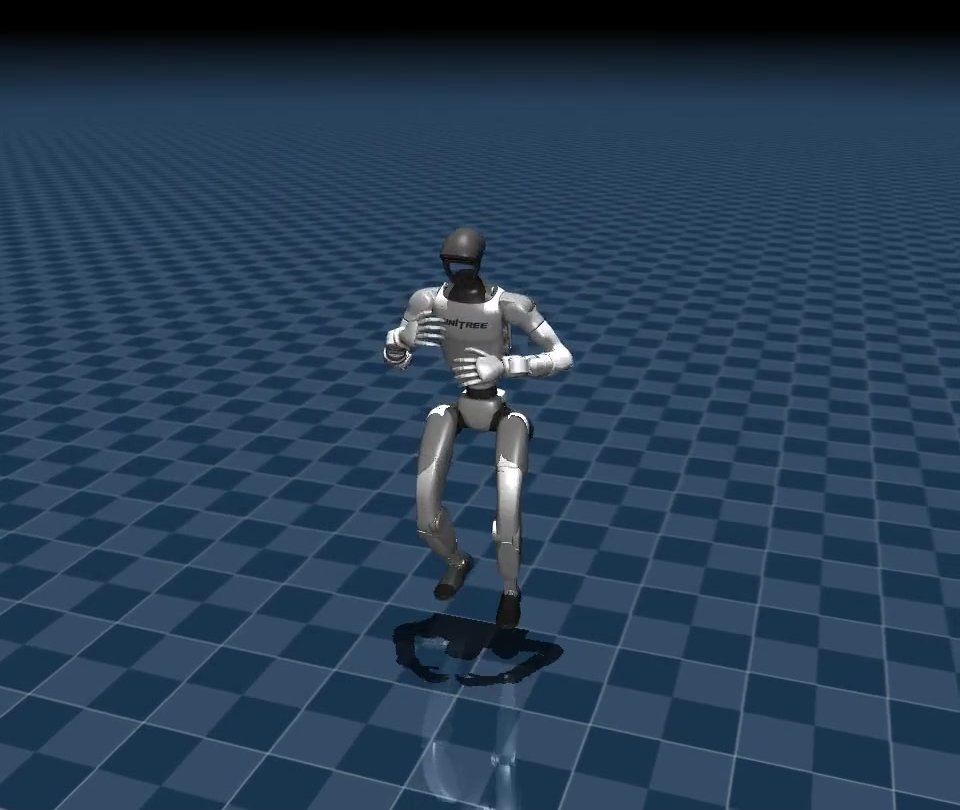
The real G1 dances to eight songs in seven styles, and returns to standing whenever the music stops.

G1 真机随 8 首歌、7 种风格起舞,音乐一停就回到站立。

REAL ROBOT · LIVE MICROPHONE真机 · 麦克风实时收音80 s

Switch tracks, stop the music随时切歌,随停随起

A loudspeaker plays the music and the robot hears it through a microphone: Dai folk, Locking, then Hip-hop, switched and stopped live. Play with sound.

音箱放歌,机器人用麦克风收音:傣族民乐 → Locking → Hip-hop,现场切歌、停歌。点击播放,结合音乐观看。
Internships实习经历

UBTECH 优必选

Jun — Oct 2026 · UBTECH2026 年 6 月 — 10 月 · 优必选科技

VLA / Embodied AI Algorithm Intern

VLA 具身智能算法实习生

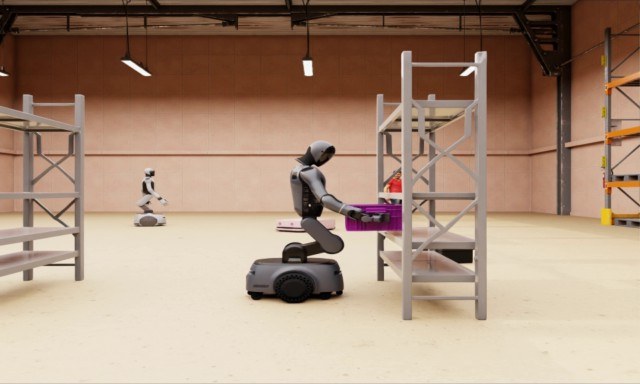
Can a robot produce its own training data and then learn from its own mistakes? I worked on this with UTars, UBTECH's dual-arm mobile robot, on a task of moving boxes between shelves of different heights in simulation.

Data without teleoperation. A motion planner moves both arms, the torso and the base together, runs in randomly varied scenes, and keeps only clean runs as demonstrations. If the box tilts or hits the shelf, it notices, plans a fix from where the robot is, and finishes the task; these recoveries become training data too.

Learning from its own attempts. Following RECAP, a separate model learns to judge whether each moment of a run is going well, and the vision-language-action (VLA) policy is retrained to favour the good moments, with the planner taking over when it fails. After two rounds, runs ending with the box placed exactly right rose from 35% to 79%.

Moving smoothly while thinking. The policy needs time to compute its next actions, which can make the robot pause or jerk. With training-time real-time chunking, it learns to continue smoothly from the actions already sent to the robot.

机器人能不能自己生产训练数据,再从自己的失败中学习?我在优必选的 UTars 双臂移动机器人上研究这个问题,任务是在仿真中把箱子在不同高度的货架之间搬运。

不靠遥操作采数据。运动规划器同时协调双臂、躯干和底盘,在随机变化的场景中反复执行,只保留干净的轨迹作为示范。箱子倾斜或碰到货架时,它会发现问题、从当前姿态重新规划补救动作并完成任务,这些恢复过程也会成为训练数据。

从自己的尝试中学习。借鉴 RECAP,先训练一个模型判断执行过程中每一刻的进展好坏,再让 VLA(视觉-语言-动作)策略重新训练、偏向表现好的动作;策略失败时由规划器接管。两轮后,箱子严格放到位的比例从 35% 提升到 79%。

边思考边流畅动作。策略计算下一段动作需要时间,容易让机器人停顿或抖动。训练时 RTC(实时分段)让策略学会从已经发给机器人的动作自然接续。

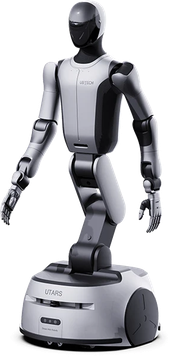
UTars dual-arm mobile robot / UTars 双臂移动机器人
UTars dual-arm mobile robotUTars 双臂移动机器人

Automated Demonstration Generation自动化示范生成

PLAN规划

Coordinated planning at scale全身协同规划与自动数采

The planner carries the box between shelves by moving both arms, the torso and the base together. Scenes vary on every run and each result is checked automatically, so demonstrations need no human teleoperation.

规划器协调双臂、躯干和底盘,把箱子在货架之间搬运。每次执行的场景都会随机变化,结果自动检查,示范无需人工遥操作。

RECOVER恢复

Recover and resume the task自主恢复,续接原任务

The box touches the shelf while being placed. The system detects it, backs off, replans from the current pose and resumes the original task; the recovery is kept as training data.

放置时箱子碰到货架。系统检测到异常后先退让,再从当前姿态重新规划并续接原任务,这段恢复过程也会保留为训练数据。

Closed-Loop VLA ExecutionVLA 闭环自主执行

UPPER SHELF上层执行

Visual policy for upper-shelf placement视觉策略驱动上层放置

The trained policy runs on its own from camera images, with no planner: it lifts the box, places it on the upper shelf and lets go.

训练好的策略只根据相机画面自主执行,不再依赖规划器:抬起箱子,放上上层货架并松手。

LOWER SHELF下层执行

Whole-body coordination across shelf levels全身协调完成跨层搬运

Reaching the lower shelf needs the arms, torso and base to move together. The policy coordinates all of them from camera images and sets the box down in place.

够到下层货架需要双臂、躯干和底盘一起配合。策略根据相机画面协调全身,把箱子放到位。

Tsinghua University 清华大学Beijing Zhongguancun Academy 北京中关村学院

Jun — Oct 2025 · Tsinghua IIIS × Zhongguancun Academy2025 年 6 月 — 10 月 · 清华 IIIS × 中关村学院

How can a robot learn tabletop manipulation when real demonstrations are scarce? I first trained Diffusion Policy on real-robot data, then built a simulated copy of the real workspace (a digital twin) to produce demonstrations at scale.

The main work combined the two for OpenVLA-family models: train on mixed real and simulated demonstrations, then keep improving in simulation with reinforcement learning, while the real demonstrations keep the policy close to what works on the real robot. With only 50 real demonstrations, early real-robot tests reached 68.75% success, versus 6.25% when training on real data alone.

真机示范很少时,机器人怎样学会桌面操作?我先用真机数据训练 Diffusion Policy,再在仿真中搭建与真实场景一致的“数字孪生”,大量生成示范数据。

主要工作是把两者结合起来训练 OpenVLA 系列模型:先用虚实混合示范训练,再在仿真中用强化学习继续提升,同时用真实示范约束策略,避免它在真机上的能力退化。只用 50 条真机示范时,初步真机测试成功率达到 68.75%,而只用真机数据训练为 6.25%。

OpenVLA · Sim-Real Co-TrainingReal robot真机演示

Real-robot manipulation真机多任务执行

Several tabletop tasks on the real robot, including picking and placing, pushing a cube and opening and closing drawers. Clips are sped up.

真机上的多种桌面任务,包括抓取放置、推方块和开关抽屉。视频为加速播放。

OpenVLA · Sim-Real Co-TrainingReal robot真机演示

Generalization beyond training conditions训练场景外的泛化表现

Compares training on real data only, ordinary sim-real co-training, and co-training with reinforcement learning in simulation, on familiar setups and on objects and conditions not seen in training.

对比只用真机数据、普通虚实联合训练,以及加入仿真强化学习的联合训练,分别在熟悉场景和训练中没见过的物体与条件下测试。